Computer Vision & ML
- YOLO (v3 / v8)
- PyTorch · TensorFlow
- OpenCV
- Fine-tuning · Roboflow
- scikit-learn · SHAP
AI engineer — computer vision, sensor data & real-time robotics.
Bachelor's thesis: a real-time perception-to-actuator control loop driving a 3D-printed robotic hand (Python, OpenCV, YOLOv8, Arduino).
Built a Python desktop tool for real-time device monitoring, data processing and visualization.
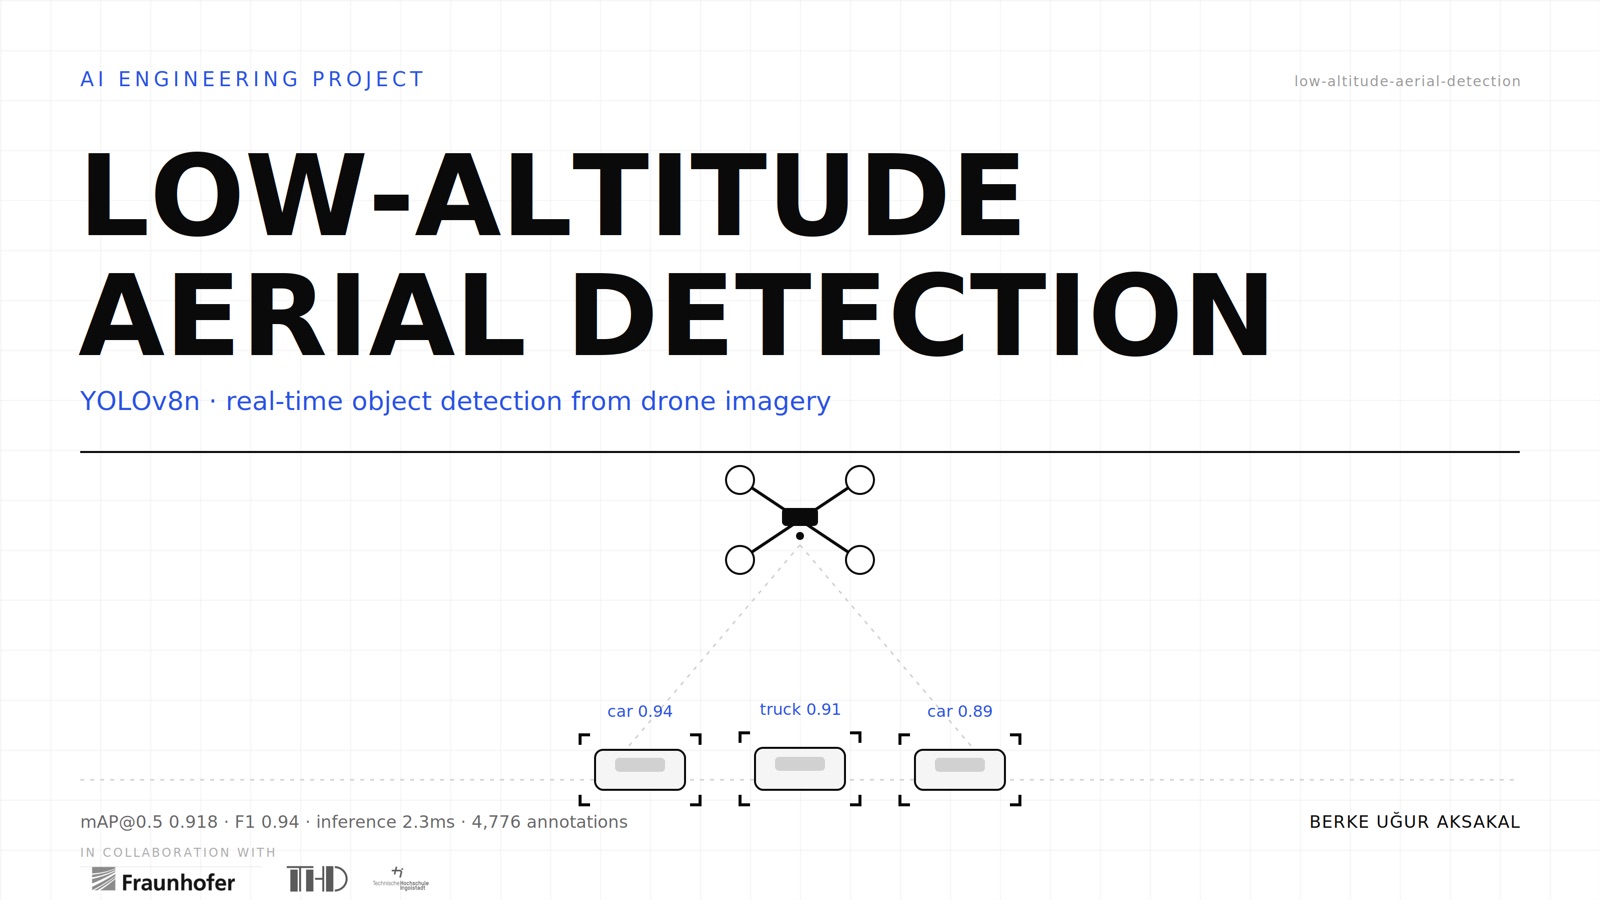
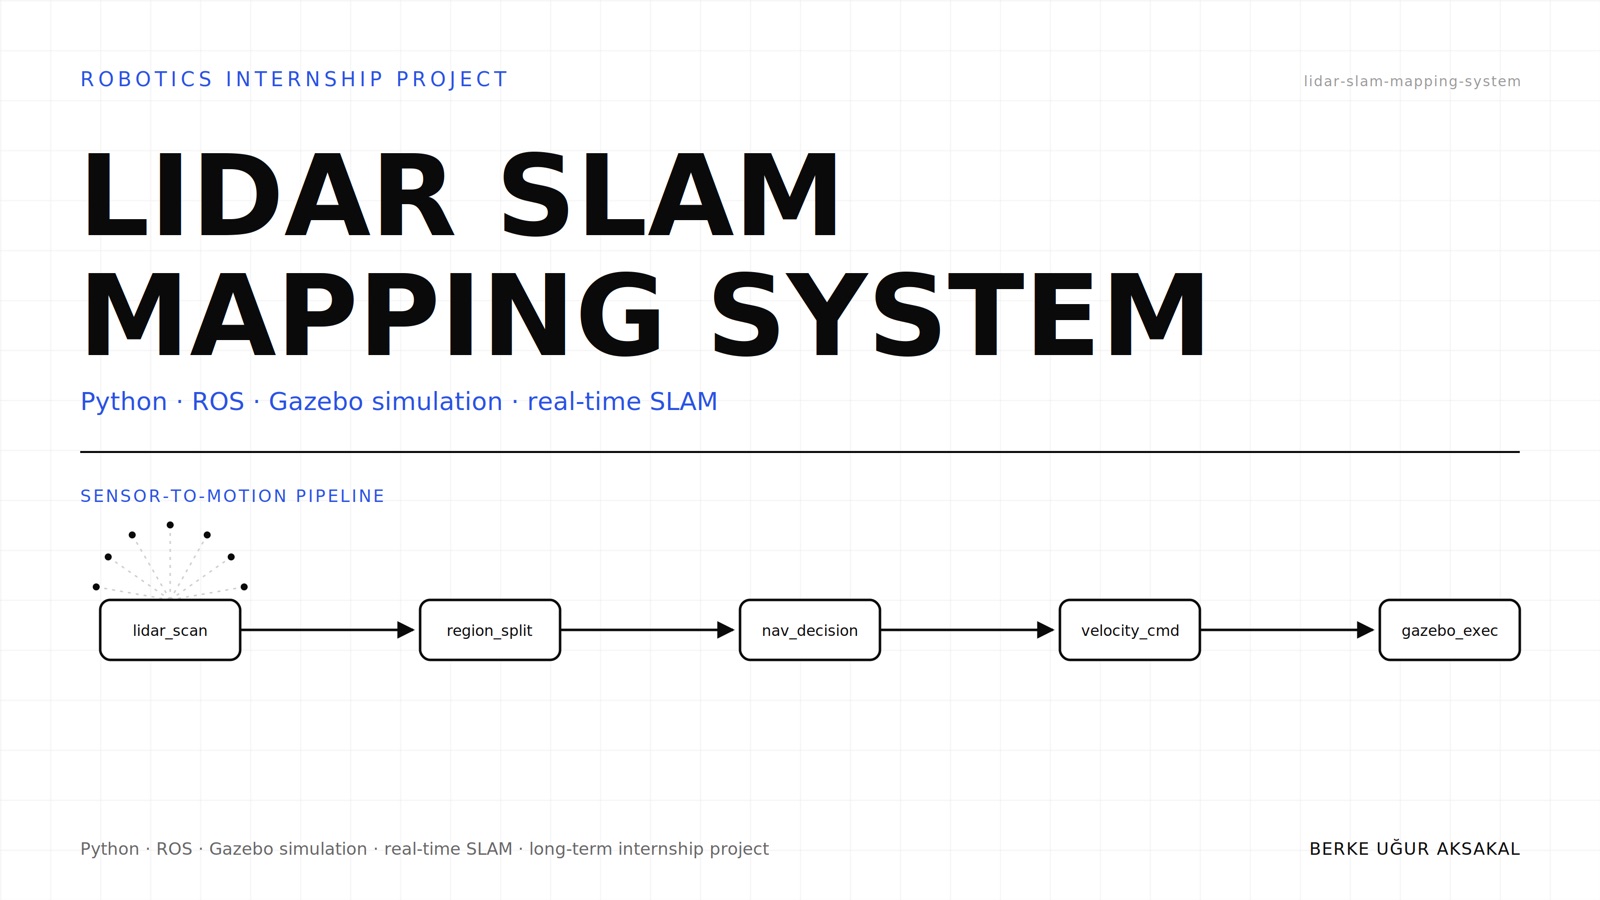
Built AI perception pipelines — YOLO-based detection and LiDAR-SLAM workflows for real-time perception. Benchmarked YOLOv3 against YOLOv8 for traffic-light detection; results presented at the IEEE TUAC 2023 conference.
Turkish (native) · English (C1) · German (A2)
I'm Berke — a Master's student in AI for Smart Sensors & Actuators with an Electrical Engineering background. I take models from a rough baseline to something that runs in the real world: full vision-to-actuator loops, YOLO detectors fine-tuned on custom data, LiDAR turned into live navigation. Experience from long-term internships at NISO and Baylan, and an academic–industry project with Fraunhofer IVI.